Robotics, physical AI, and startup hubs in Japan: Summer 2026
A summer in Tokyo, Osaka, and Yokohama researching robotics, physical AI, startup hubs, CEDEC 2026, and the Developer Experience robot build.
Updates, developer documentation, robotics, and app development from Developer Experience.
A summer in Tokyo, Osaka, and Yokohama researching robotics, physical AI, startup hubs, CEDEC 2026, and the Developer Experience robot build.
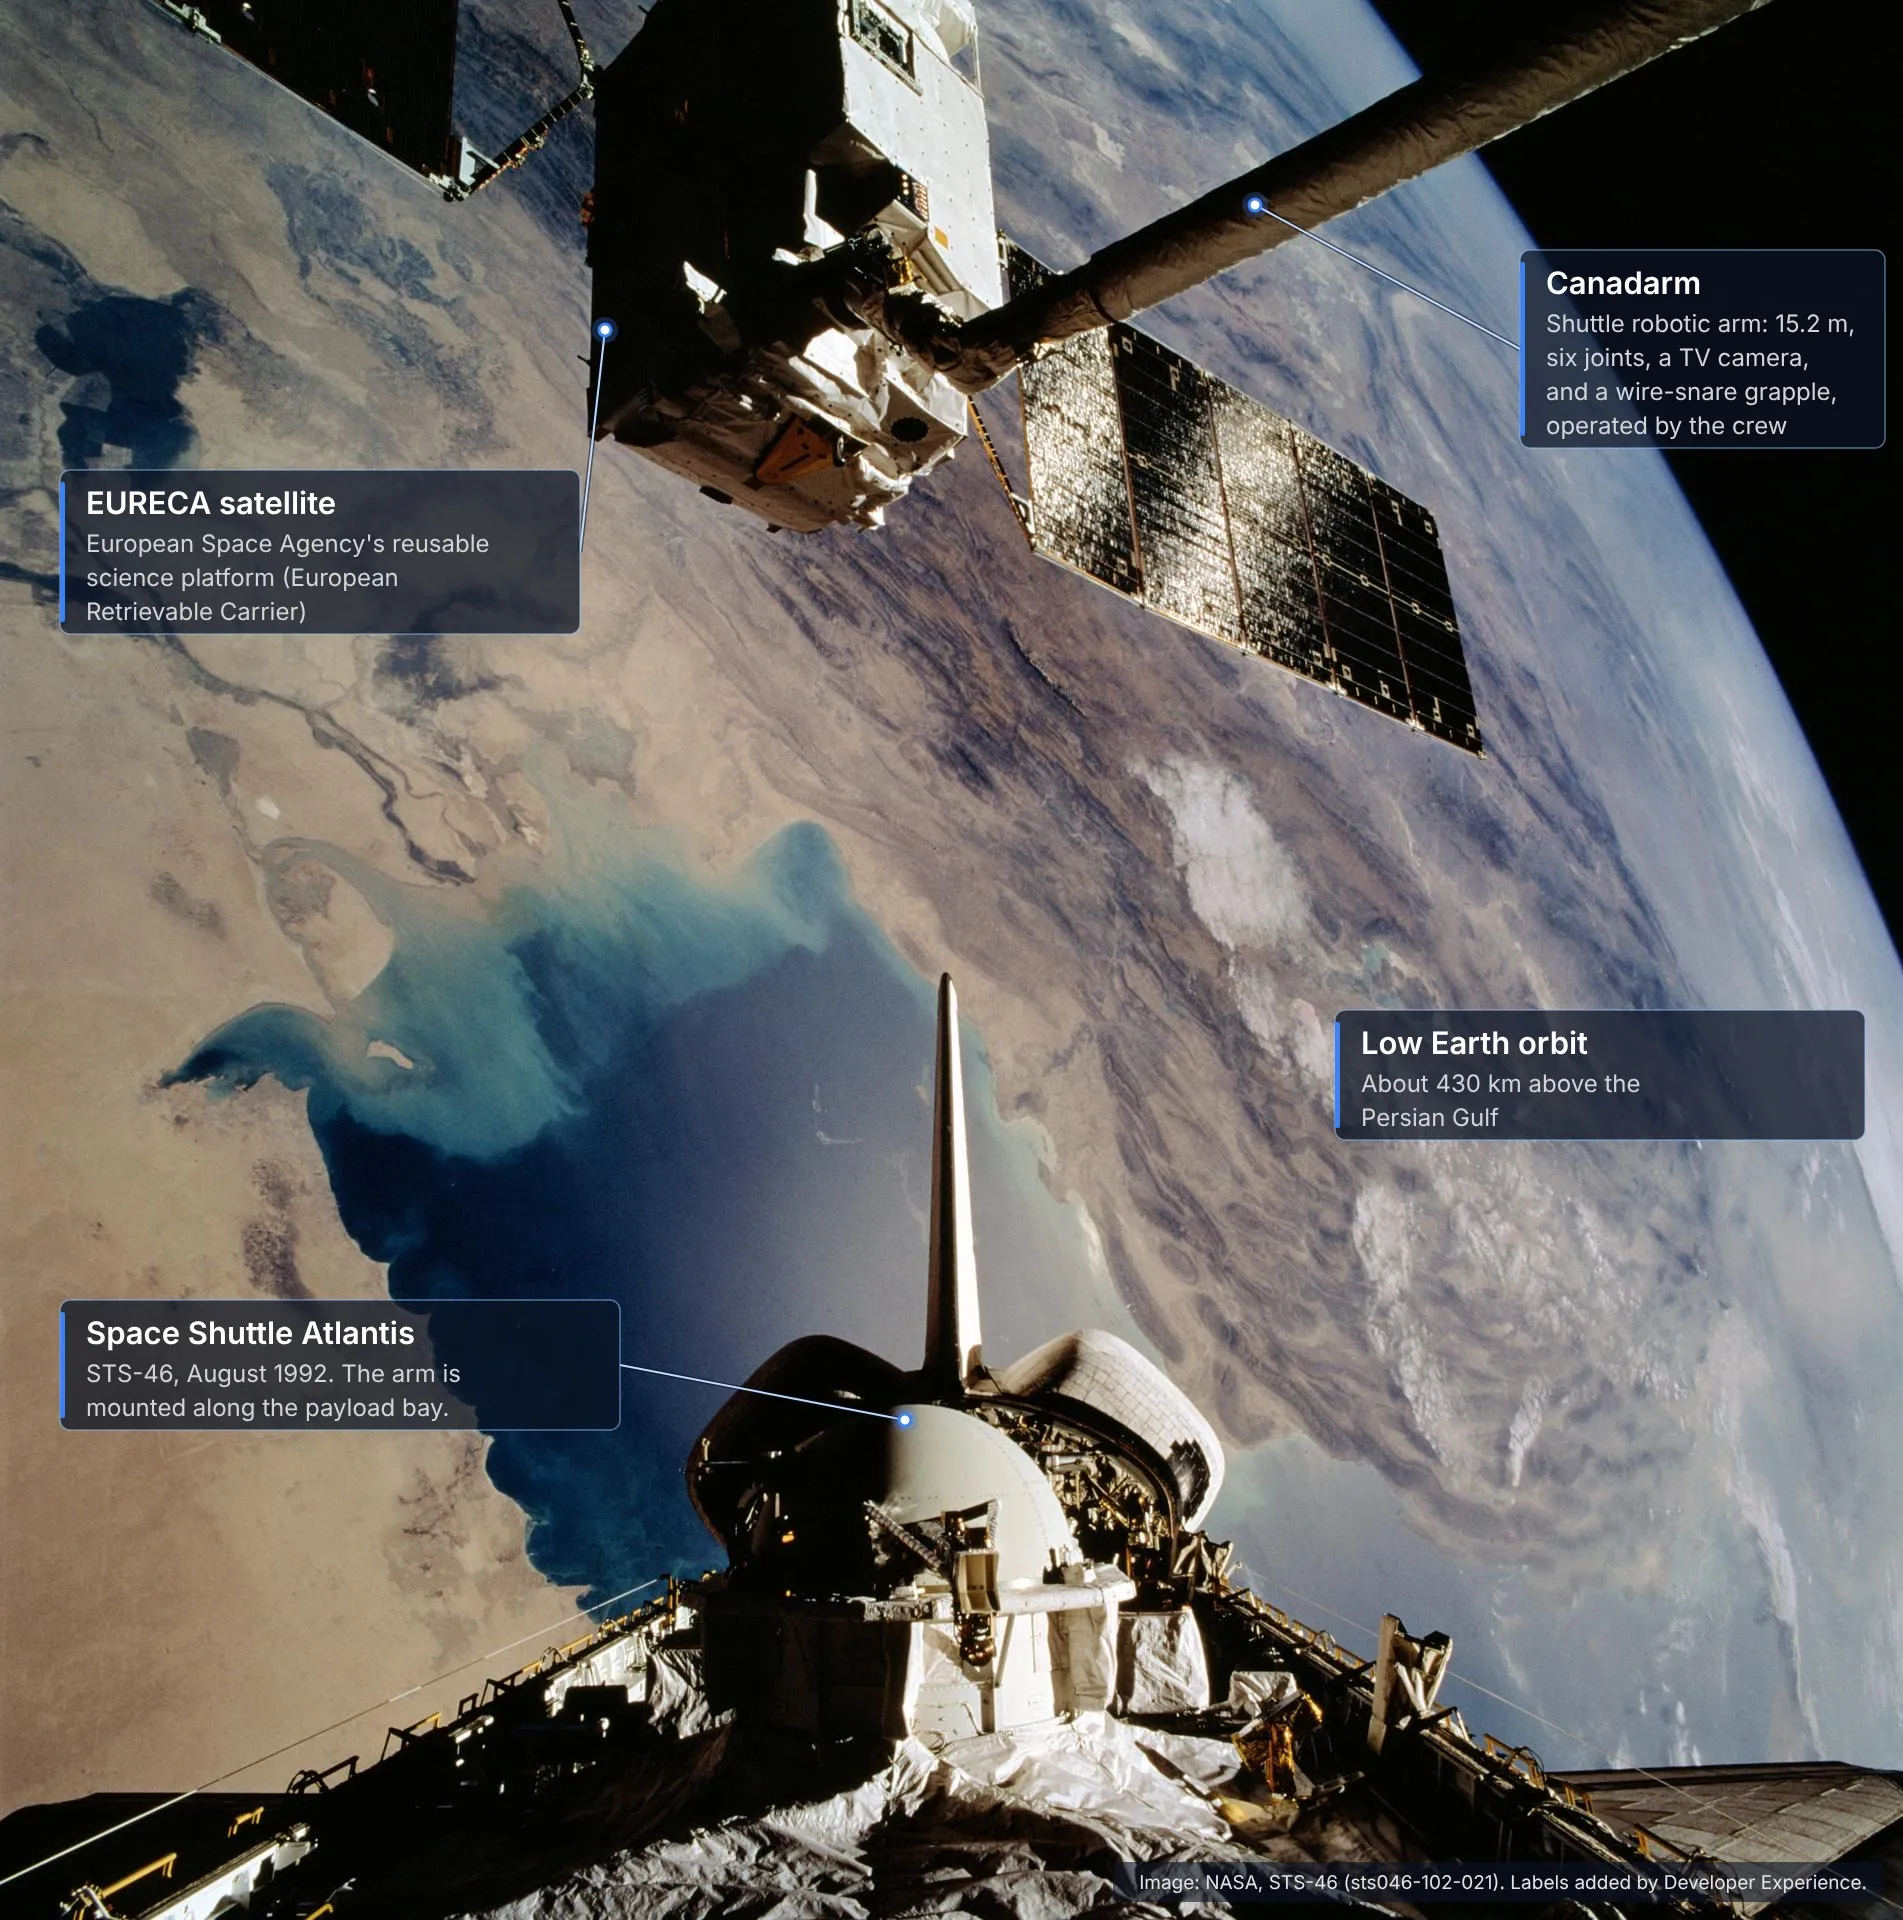
We attended the space robotics panel at Seattle Space Week where they discussed the development and testing of space shuttle mounted robots, onboard processing, radiation, and physical AI in space.
The tech events we're attending in Seattle and Japan from June through August 2026.
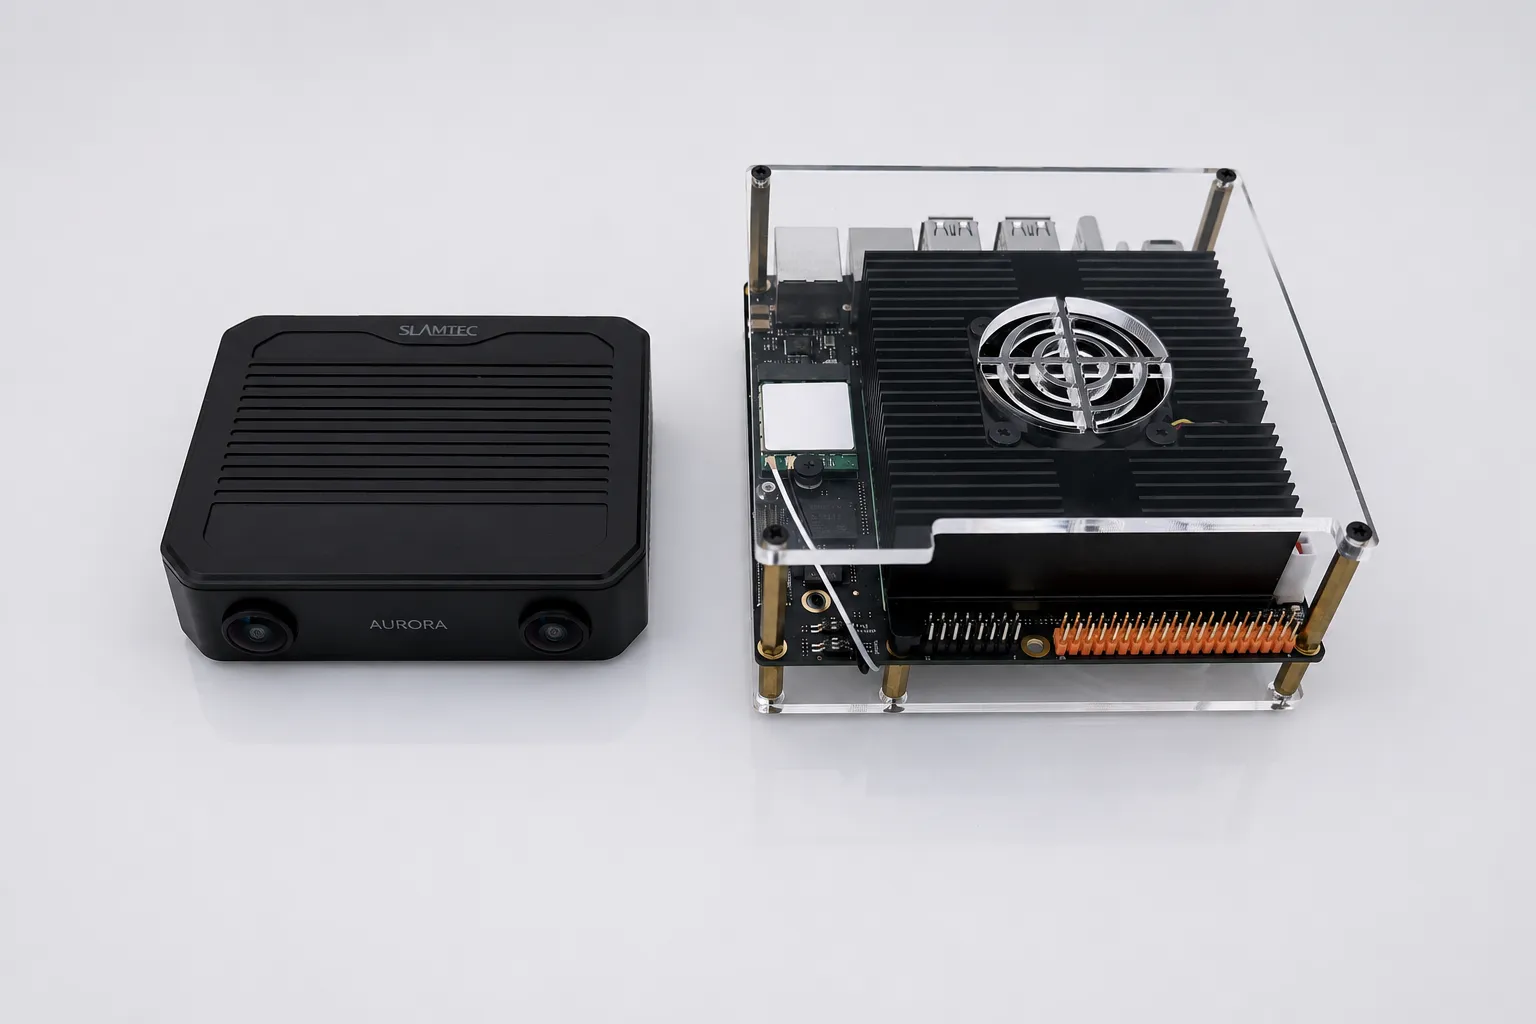
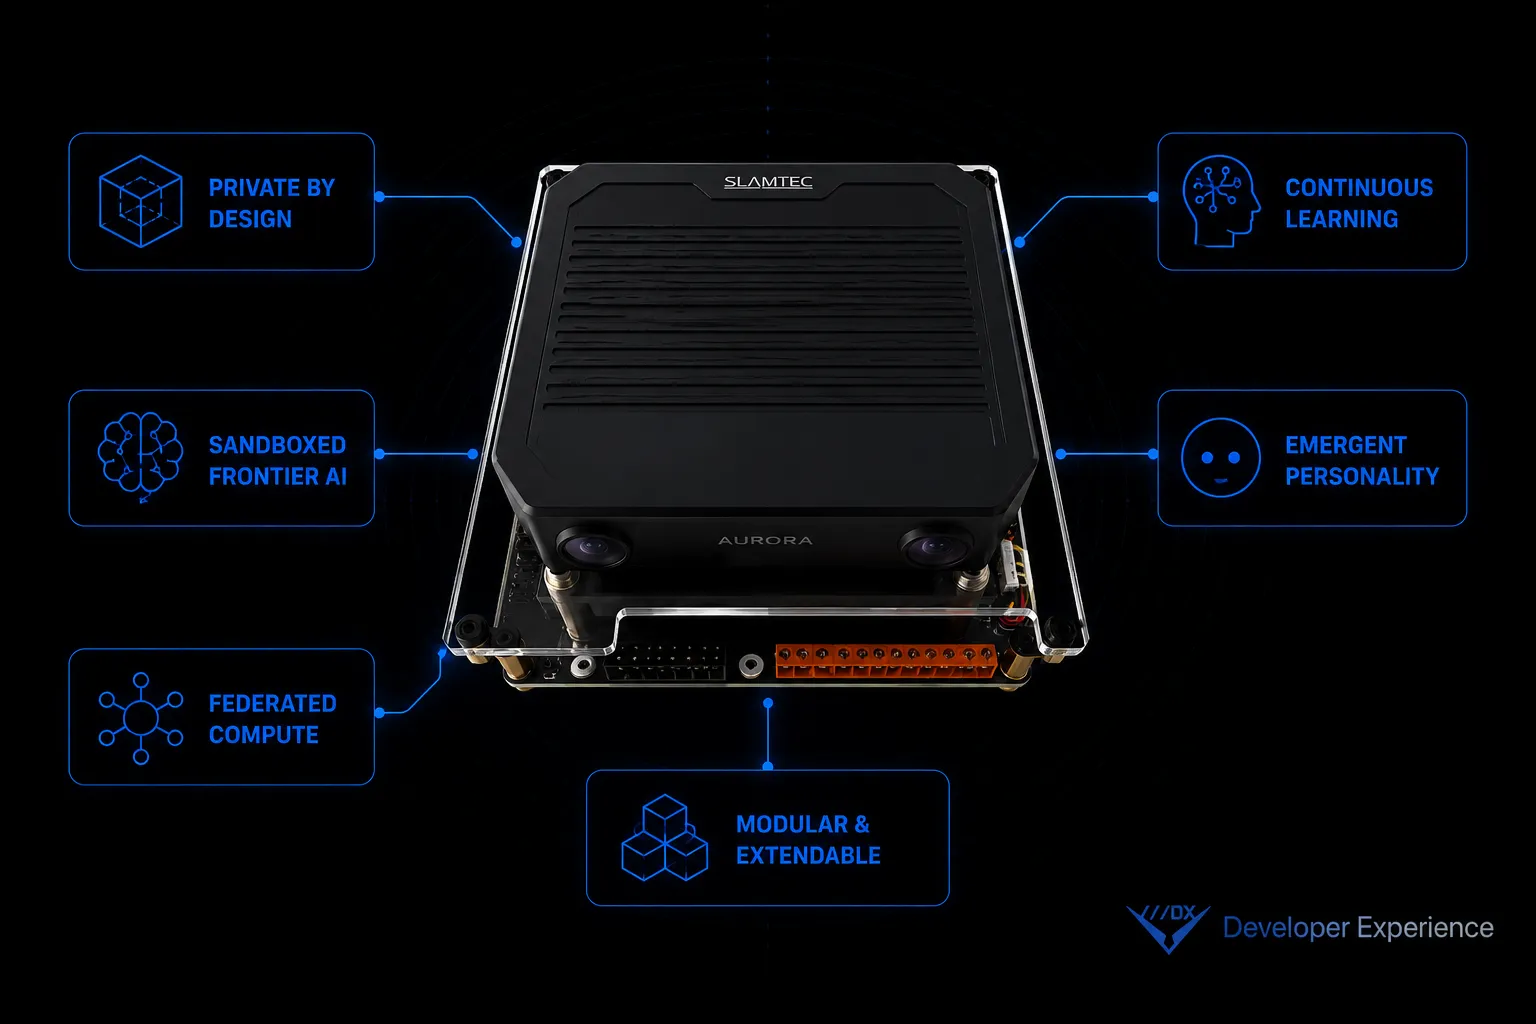
We set up the SLAMTEC Aurora S on the D-Robotics RDK S100P, and starting viewing perception data in the SLAMTEC Remote Visualizer app.
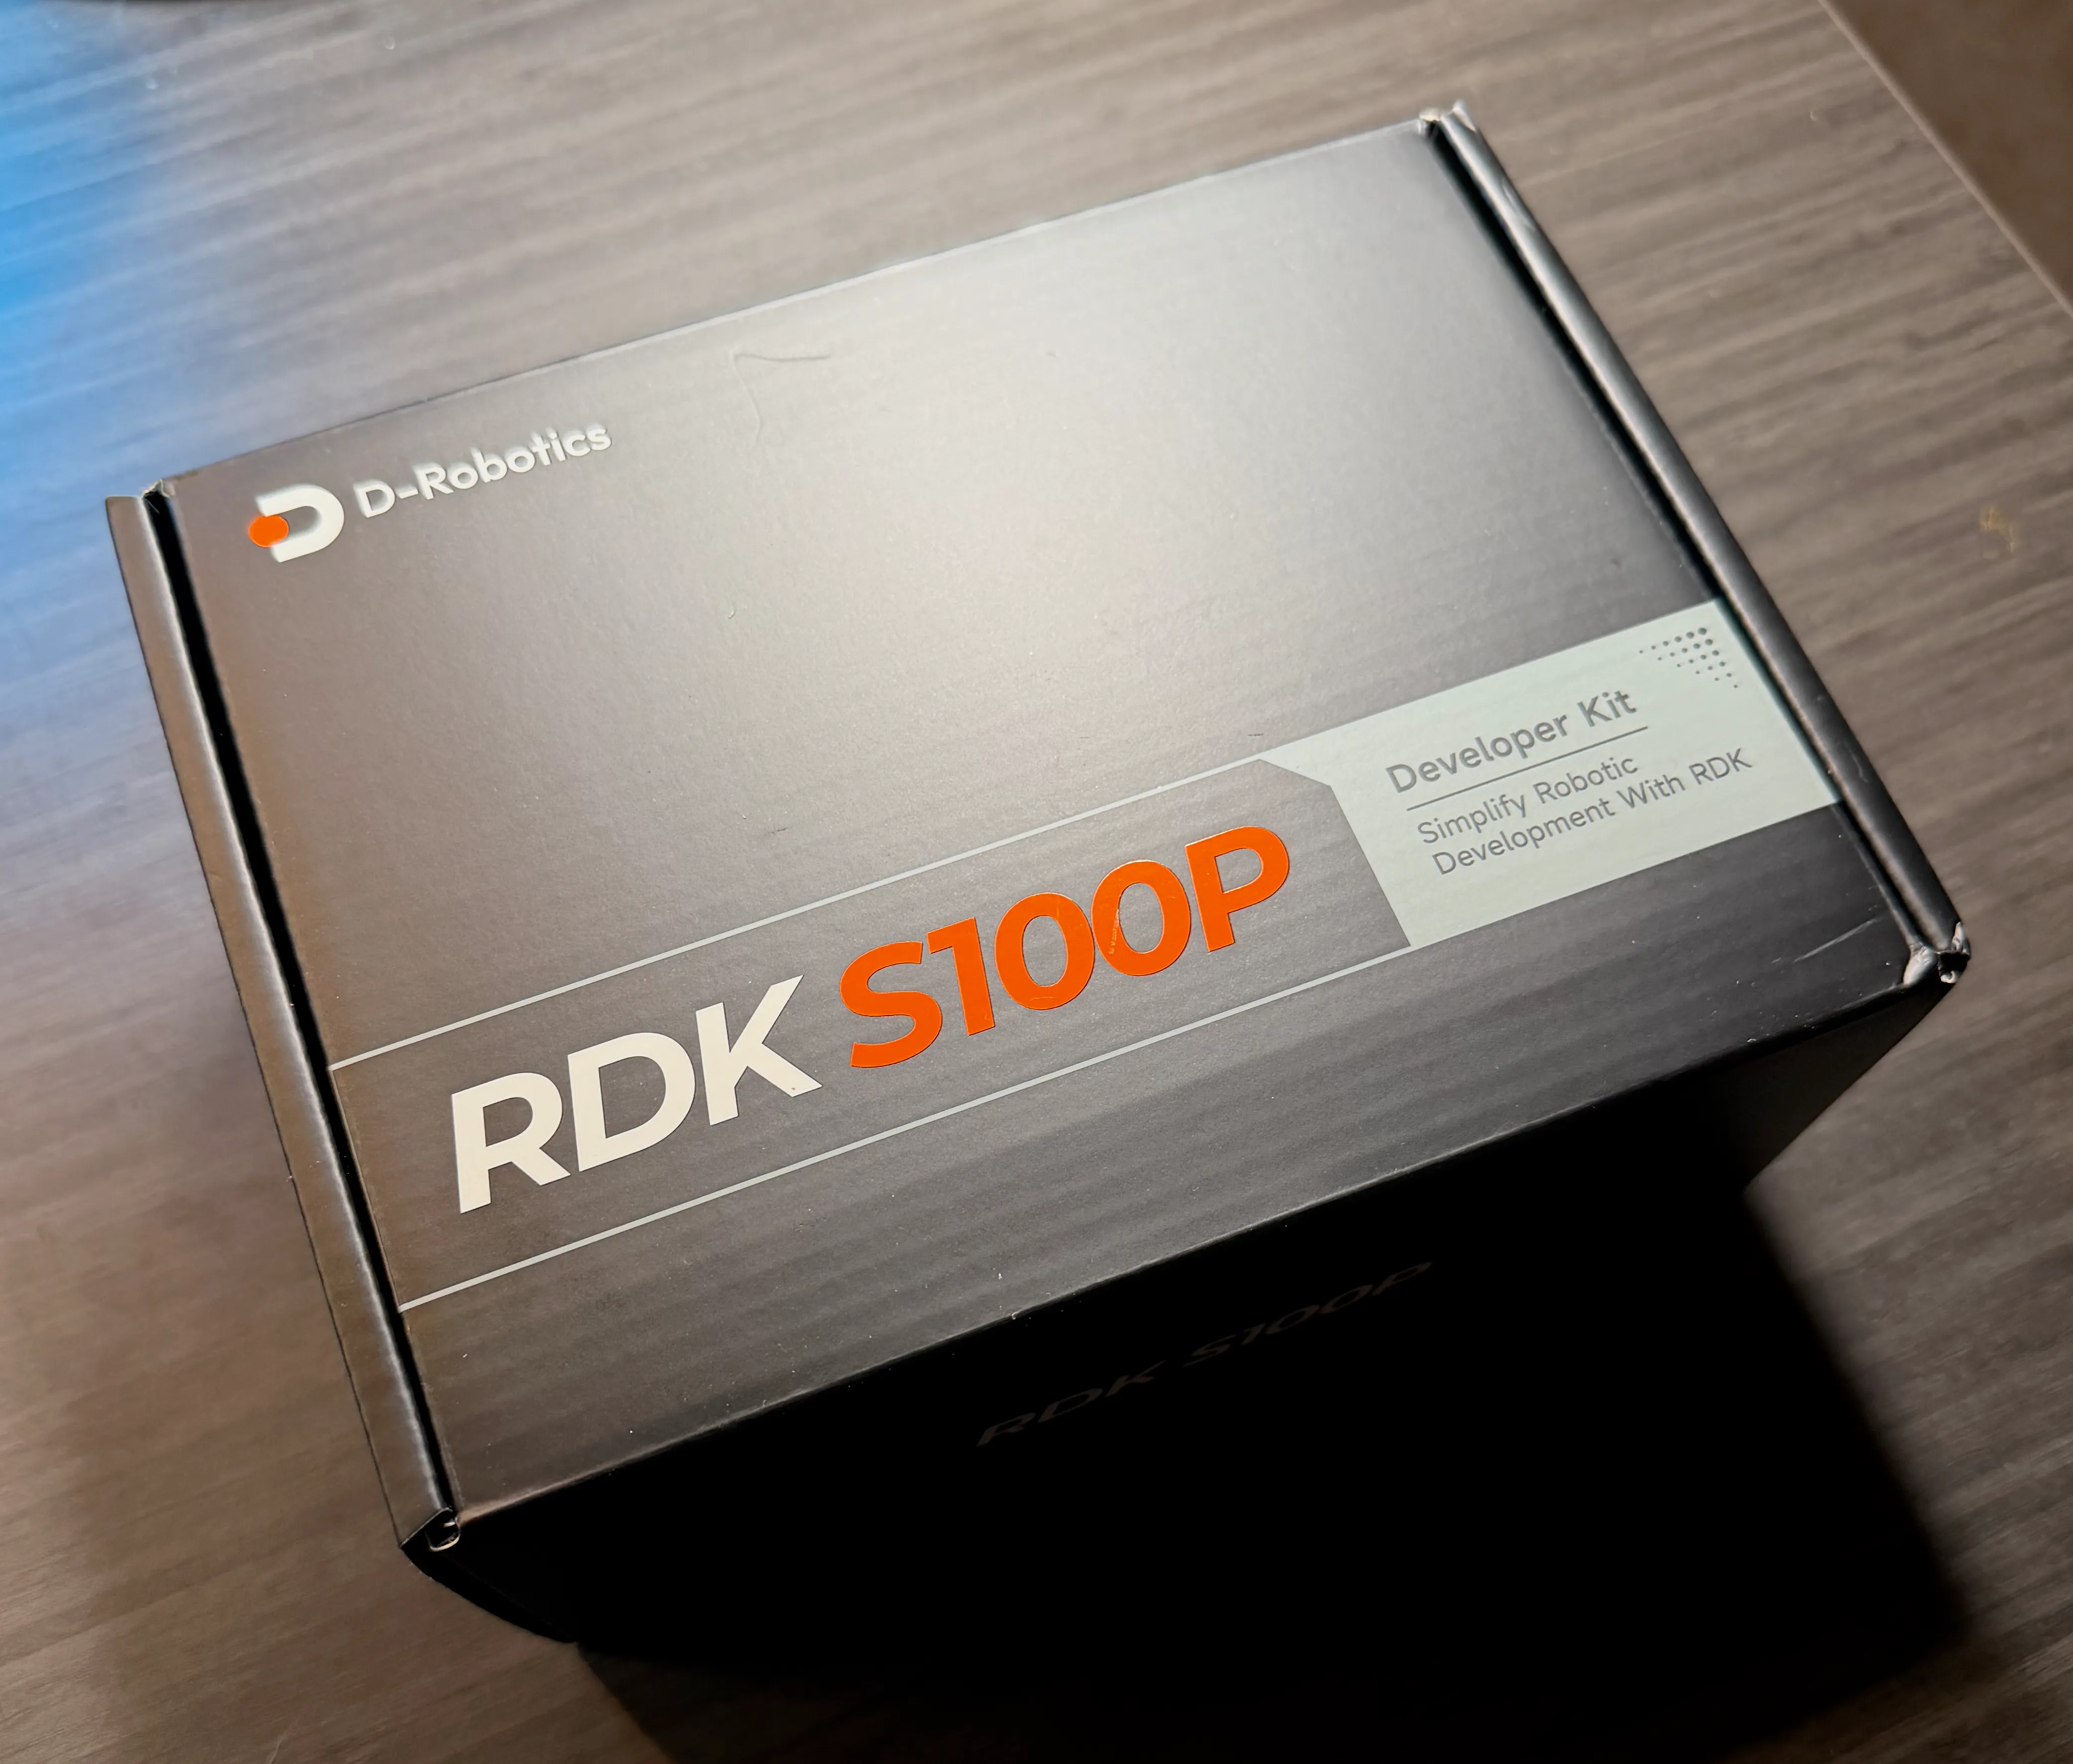
We unboxed the D-Robotics RDK S100P, connected basic peripherals, and started up the robot brain for the first time. From there, we did a deep dive into networking and setting up third-party drivers on the RDK.
We’re building an AI embodied robot using the D-Robotics S100P RDK and the Booster K1 humanoid platform. This project is a structured, phase-based exploration of embodied intelligence, starting with core compute and perception, and progressing toward mobility, XR integration, and full physical interaction.
A developer walkthrough for NASA's APOD REST API: fetch the daily astronomy image or video, render it, and surface key metadata in a simple web UI. The example is intentionally portable, and covers practical patterns like DOM caching, helper utilities, and defensive handling for images and videos.